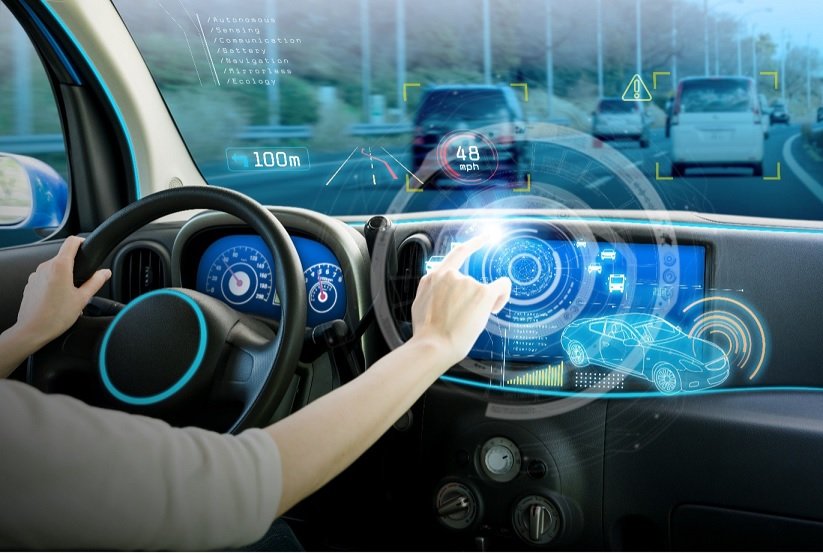
Automotive head-up displays (HUDs) project driving information into the driver’s field of view, keeping essential data visible without requiring a glance down at the instrument panel. Some systems include adjustable optical components or mechanisms that position a combiner or projection module. These functions require compact drives that deliver controlled movement. This movement must remain predictable during repeated adjustments and temperature changes inside the vehicle.
A qualified Stepper Motor Manufacturer can help automotive designers match motor characteristics to HUD requirements. Selection should consider step angle, torque, gearbox configuration, control method, noise, installation space, and environmental durability. The right combination supports accurate movement within the limited space behind the dashboard.
Where Stepper Motors Fit in HUD Systems
A HUD combines a display source, optical elements, a projection path, and a dashboard housing. Depending on its architecture, it may use mechanical adjustment to raise or lower a combiner, reposition an optical module, or support calibration. Not every HUD includes motorized adjustment, so engineers should identify which components need movement.
A stepper motor moves in defined increments in response to electrical pulses. A controller commands movement by specifying the number and direction of steps. With suitable gearing, a compact motor can move a HUD component through a controlled range, making it useful for repeatable positioning.
Why Stepper Motors Support Precise Positioning
Stepper motors provide incremental motion, allowing a controller to divide movement into small commanded steps. When correctly sized and energized, they can also hold a position against the mechanism’s load. This is useful when a HUD component must remain stable or move between predefined positions.
Key specifications include step angle, holding torque, speed, acceleration, and duty cycle. A smaller step angle does not automatically guarantee greater system accuracy. Mechanical tolerances, friction, gear backlash, load variation, and mounting rigidity also affect the final position. Engineers should evaluate the complete mechanism.
Microstepping divides each full step into smaller increments by controlling phase currents. It can make movement smoother and reduce vibration, although it does not guarantee equivalent gains in absolute positioning accuracy. The motor, driver, load, and control strategy must work together.
The Role of Gearboxes and Control Systems
A gearbox adapts motor speed and torque to the HUD mechanism. A reduction gearbox can increase output torque and provide finer movement. Its gear ratio, efficiency, backlash, noise, and service life should be evaluated alongside motor performance. An excessively high ratio may slow adjustment or add mechanical losses.
An experienced electric motor manufacturer can help determine whether a direct-drive motor or geared assembly is more suitable. The control system also matters. An open-loop stepper system estimates position from commanded steps; an overload or obstruction can cause missed steps and positioning errors.
Homing routines, limit switches, position sensors, or closed-loop control can help establish or verify position. Calibration can account for assembly variation and support consistent display placement. The feedback strategy depends on accuracy requirements, cost, available space, and the consequences of positioning errors.
Automotive Design and Validation Considerations
HUD components operate in demanding vehicle environments. Temperature changes, vibration, dust, and repeated cycles can affect motor durability. Designers should confirm that motor materials, bearings, lubrication, connectors, and drive electronics suit the intended conditions and service life.
Noise is important because clicking, resonance, or vibration near the dashboard can affect cabin comfort. Smooth acceleration profiles, suitable current control, vibration isolation, and careful gear design can reduce unwanted sound. Packaging constraints include motor dimensions, shaft configuration, mounting features, wiring, and heat dissipation.
Prototype testing should reflect real operating conditions. Checks include positioning repeatability, movement noise, cycle life, temperature performance, vibration resistance, and behavior under abnormal loads. Testing the motor alone may overlook issues caused by the gearbox, housing, or connected mechanism. Complete-assembly validation gives a more realistic performance assessment.
Conclusion
Stepper motors provide controlled movement in HUD mechanisms that adjust optical or display components. Their incremental operation, holding capability, and compatibility with geared drives suit selected automotive designs. Reliable performance depends on control electronics, mechanical tolerances, feedback, and environmental protection. Careful specification and system-level validation help HUD mechanisms move smoothly and maintain their intended positions.